II. Driver Configuration
This section covers basic driver setup, including motor identification and parameter configuration.
Powering Up the Controller
- Connect battery (if not already connected)
- Activate power switch
- Verify motor sound indication
- Connect USB/CAN cable
- Verify Launchpad connection settings
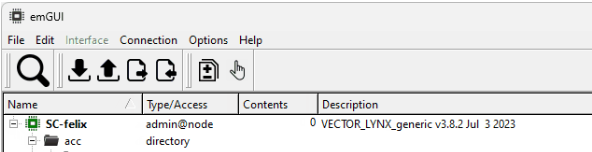
- Confirm controller detection in emGUI
Motor Identification
Covers the minimum to make the motor work. Required scripts are located in c:\silixcon\scripts\configuration\First_run\.
Alternatively, check the guided indentification
Sensor Configuration
Required only for VECTOR drive (FOC) firmware. Skip for BLDC firmware. BLDC supports hall sensors only.
Execute 1-Motor_sensor_selection.ys and follow prompts.
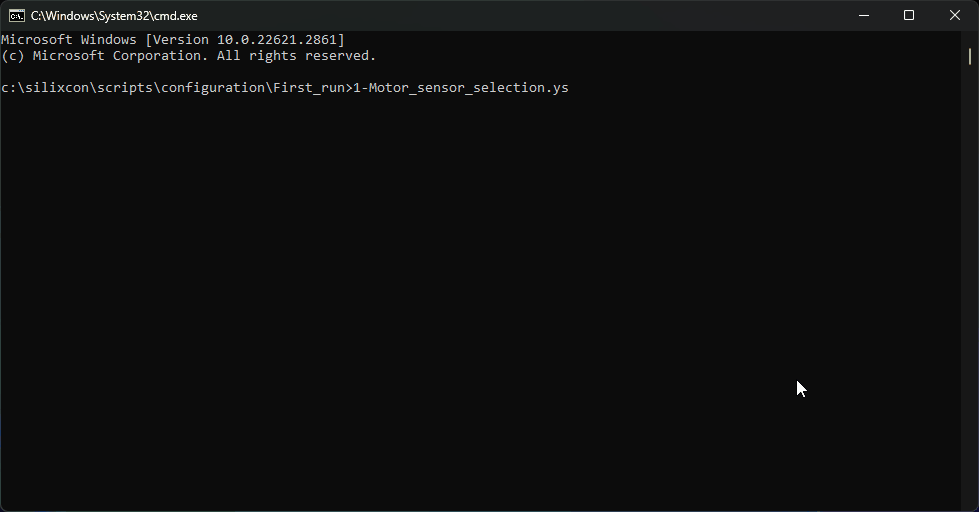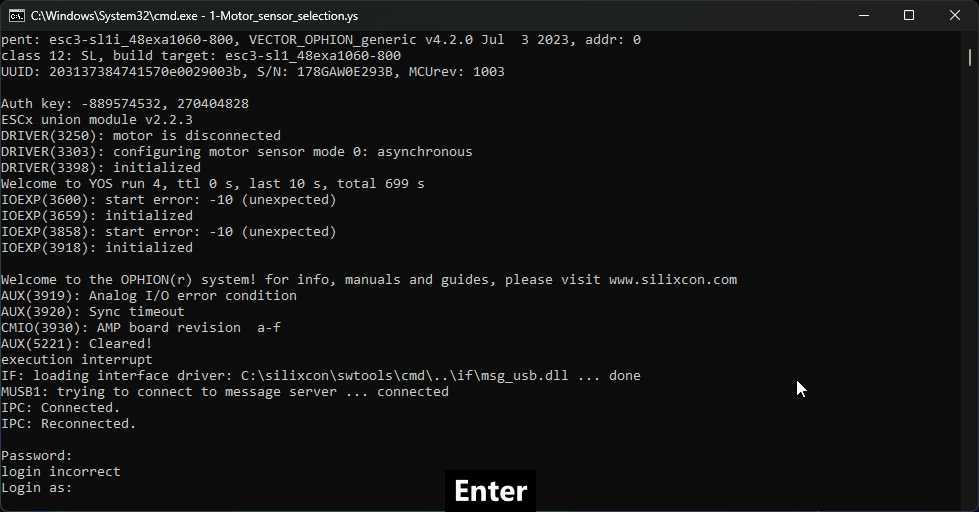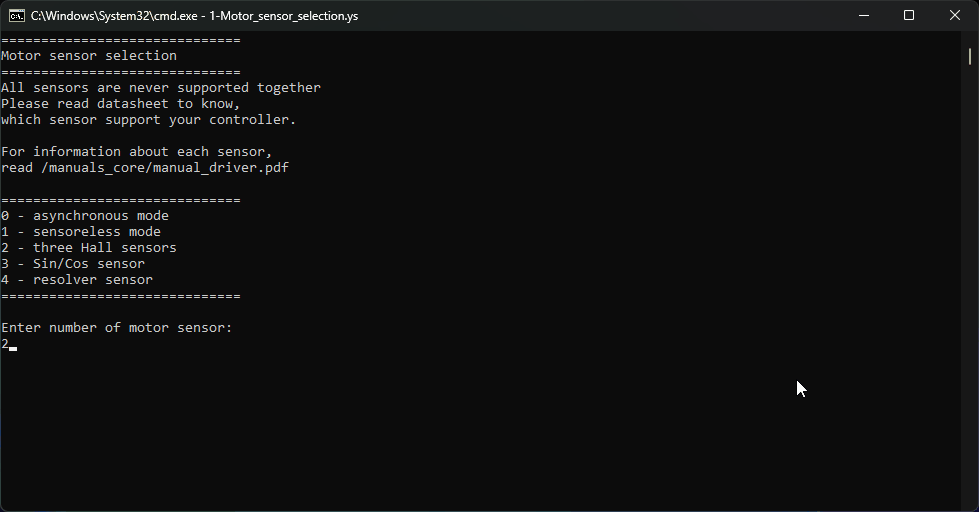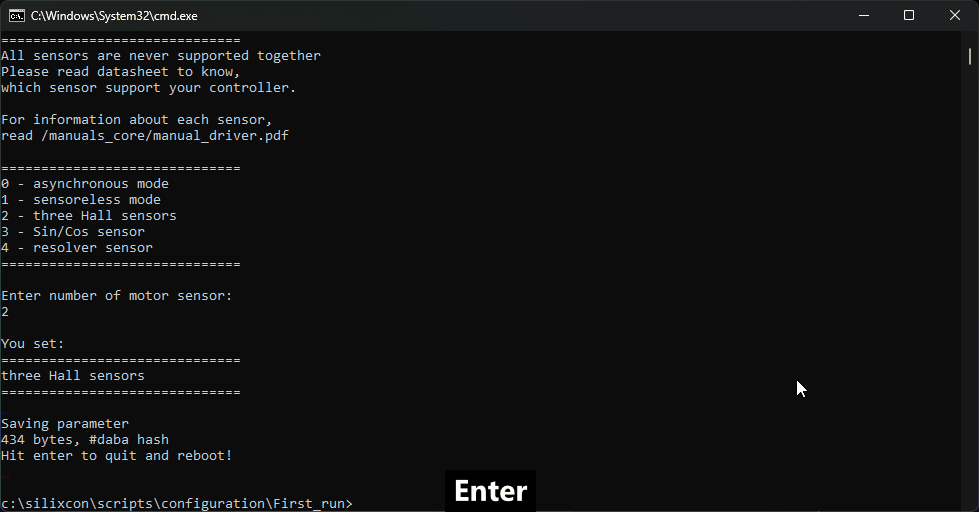
Script Functions:
- Controller authentication
- Sets
/driver/prestto specified value
Sensor support varies by application modification (mod). Details
Stator Current Configuration
/driver/iref: Maximum stator current [A] (amplitude, not RMS)/driver/ipeak: Must exceediref(recommend default value)
Motor Pole Pair Setting
Set /driver/motor/pp to motor's pole pair count. Required for accurate speed measurement and limiting.
Automatic Identification
Execute 2-Motor_identification.ys and follow prompts.
- Battery must operate within
ubminandubmaxlimits - Ensure unloaded motor with free rotation
Motor Thermal Protection Setup
Optional but recommended. Prevents motor thermal damage.
/driver/limiter/mtemplo: Initial limitation temperature/driver/limiter/mtemphi: Maximum limitation temperature
Values in [ohm] (motor temperature sensor resistance).
Monitor temperature via /driver/motor/Rthermistor.
Battery Limiter Configuration
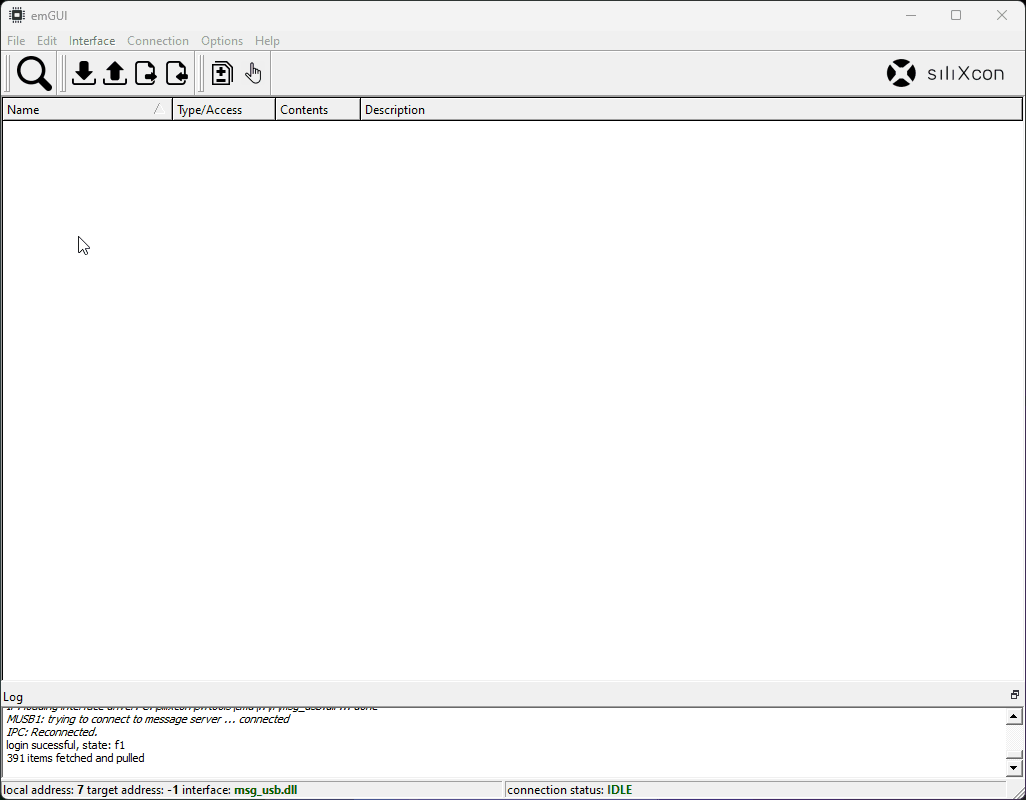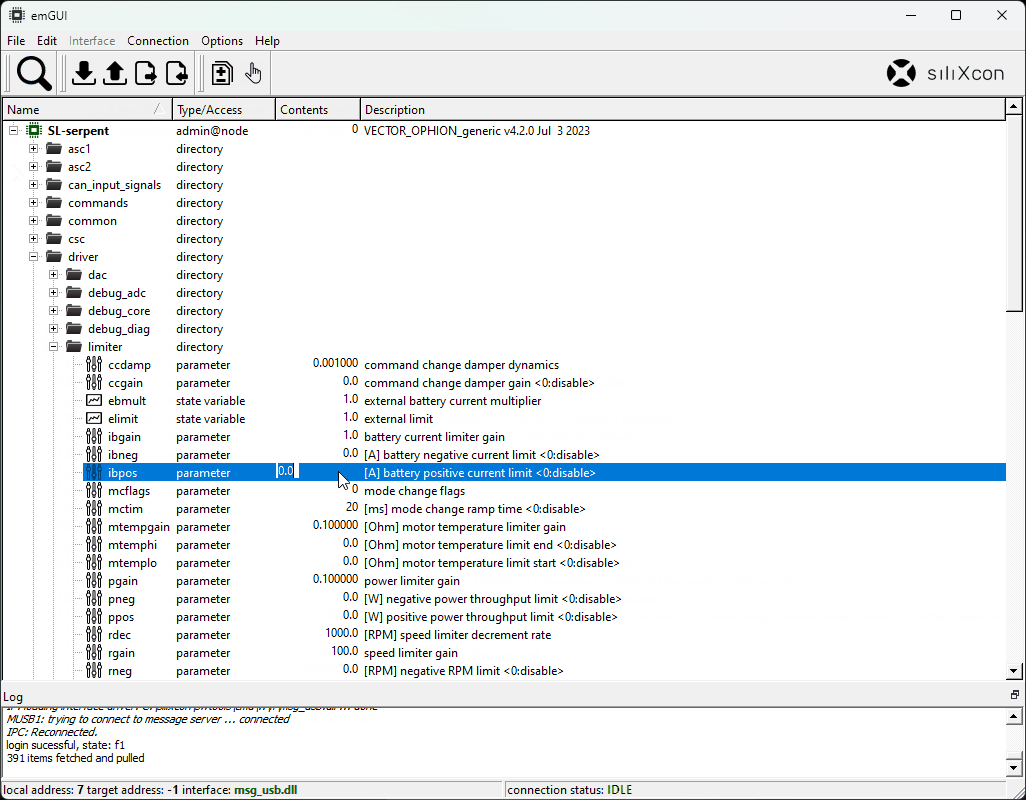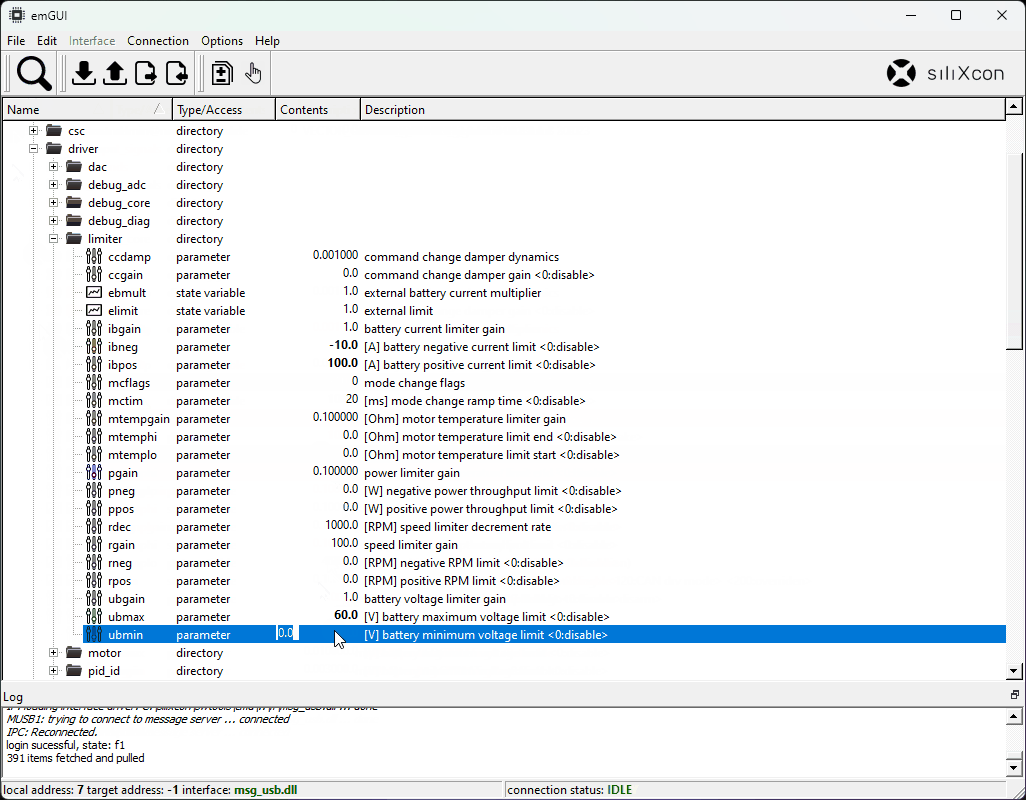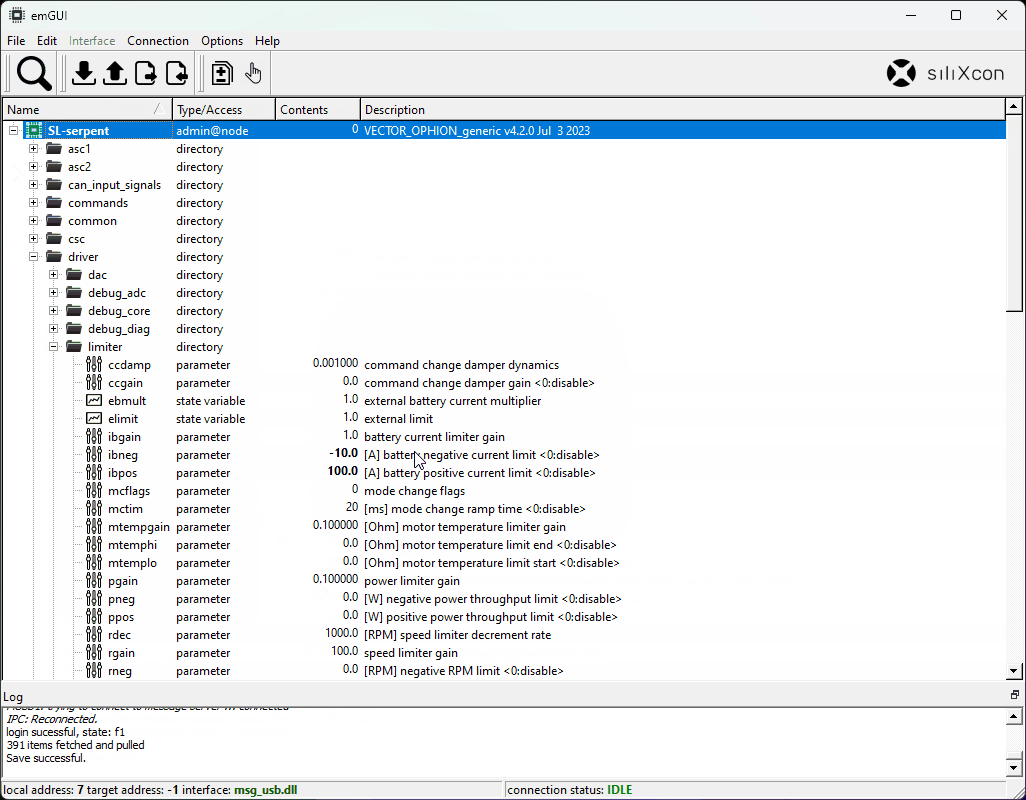
Optional settings. Zero values disable DC-side voltage/current limitation.
/driver/limiter/ubmax: Maximum battery voltage/driver/limiter/ubmin: Minimum battery voltage/driver/limiter/ibpos: Maximum discharge current/driver/limiter/ibneg: Maximum regeneration current (negative value)
Rotation Direction
Forward direction is defined by spin-up rotation direction during the identrun procedure.
If you saw the opposite direction:
Change by wire swap
- Swap any two motor phases
- Requires re-identification
Change by parameter
Invert /driver/ipeak value:
- Forward:
/driver/ipeak= 200 [A] - Reverse:
/driver/ipeak= -200 [A]
Physical wire swap is preferred. Changing with ipeak can lead to unexpected reversing, if you lose the configuration with this setting.